Table of Contents
The actuator must move and hold the selected valve under worst-case differential pressure while matching the control signal, speed, duty and safe-state requirement. For electric control valve actuator, begin with “Identify Rotary or Linear Motion” and then “Calculate Required Torque or Thrust.” Together, “Identify Rotary or Linear Motion” and “Calculate Required Torque or Thrust” define the electric control valve actuator evidence needed before “Match Stroke and End Positions.”
After “Match Stroke and End Positions,” the electric control valve actuator workflow continues to “Choose Modulating or On-Off Duty” and ends at “Verify Environmental and Manual Operation.” The move from “Match Stroke and End Positions” to “Verify Environmental and Manual Operation” explains the electric control valve actuator logic behind this H1.
Identify Rotary or Linear Motion
Confirm valve travel, angle, stem interface and direction. Mechanical adapters must transmit motion without lost travel or side loading. For “Identify Rotary or Linear Motion,” the electric control valve actuator team ties assumptions to field evidence. Its “Identify Rotary or Linear Motion” record names the source, unit and “Identify Rotary or Linear Motion” exception owner.
- Verify confirm valve travel.
- Document stem interface and direction.
- Compare mechanical adapters must transmit motion without lost travel or side loading.
Calculate Required Torque or Thrust
Use valve data at maximum differential pressure, seal friction and shutoff condition. Apply a documented margin rather than an arbitrary oversized motor. Use drawings and measurements to complete “Calculate Required Torque or Thrust” in electric control valve actuator. A written “Calculate Required Torque or Thrust” decision keeps installation and operations aligned.
- Verify use valve data at maximum differential pressure.
- Document seal friction and shutoff condition.
- Compare apply a documented margin rather than an arbitrary oversized motor.
Match Stroke and End Positions
The actuator must achieve full required travel without driving the valve into mechanical stops. Set and verify limit switches during commissioning. A plausible “Match Stroke and End Positions” result can hide a electric control valve actuator error. Store “Match Stroke and End Positions” limits, test conditions and exception ownership.
- Verify the actuator must achieve full required travel without driving the valve into mechanical stops.
- Document set and verify limit switches during commissioning.
Choose Modulating or On-Off Duty
Control valves need suitable positioning resolution, feedback and duty cycle. An on-off actuator is not a substitute for stable modulation. Share “Choose Modulating or On-Off Duty” evidence with the electric control valve actuator stakeholders. If “Choose Modulating or On-Off Duty” misses its basis, revise the “Choose Modulating or On-Off Duty” selection and record why.
- Verify control valves need suitable positioning resolution.
- Document feedback and duty cycle.
- Compare an on-off actuator is not a substitute for stable modulation.
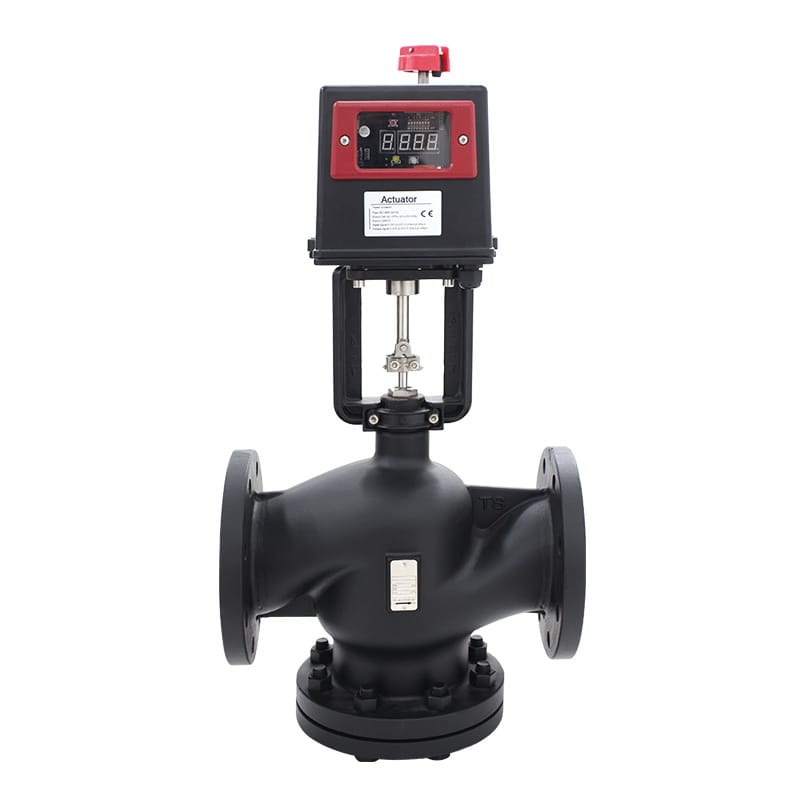
Select Control Signal and Feedback
Define floating, voltage or current command, plus position feedback and fault contacts. Confirm signal common and isolation with the controller. Give “Select Control Signal and Feedback” a dedicated electric control valve actuator acceptance test. Preserve “Select Control Signal and Feedback” values and diagnostics for a repeatable “Select Control Signal and Feedback” check.
- Verify voltage or current command.
- Document plus position feedback and fault contacts.
- Compare confirm signal common and isolation with the controller.
Check Running Time Against the Process
Fast movement can cause pressure transients; slow movement can impair temperature or pressure control. Coordinate speed with loop tuning. Treat “Check Running Time Against the Process” as a complete electric control valve actuator decision. Recheck “Check Running Time Against the Process” against electric control valve actuator pipework, controls, interfaces and service access.
- Verify fast movement can cause pressure transients; slow movement can impair temperature or pressure control.
- Document coordinate speed with loop tuning.
Define Fail Position and Power Strategy
Decide what the valve must do on power or signal loss. Spring return, capacitor return or stay-put behavior have different sizing implications. Change one “Define Fail Position and Power Strategy” variable at a time during electric control valve actuator diagnosis. The “Define Fail Position and Power Strategy” baseline separates “Define Fail Position and Power Strategy” hardware, process and installation causes.
- Verify decide what the valve must do on power or signal loss.
- Document capacitor return or stay-put behavior have different sizing implications.
Verify Environmental and Manual Operation
Specify enclosure, temperature, condensation protection and manual override. Ensure maintenance can operate the valve safely without damaging gearing. Close “Verify Environmental and Manual Operation” with a named electric control valve actuator owner. For “Verify Environmental and Manual Operation,” keep its photographs, configuration export and “Verify Environmental and Manual Operation” comparison readings.
- Verify specify enclosure.
- Document condensation protection and manual override.
- Compare ensure maintenance can operate the valve safely without damaging gearing.
Identify Rotary or Linear Motion Decision Table
| Decision | Evidence | Release condition |
|---|---|---|
| Identify Rotary or Linear Motion | Confirm valve travel, angle, stem interface and direction | Release “Identify Rotary or Linear Motion” only after its electric control valve actuator evidence is accepted |
| Calculate Required Torque or Thrust | Use valve data at maximum differential pressure, seal friction and shutoff condition | Release “Calculate Required Torque or Thrust” only after its electric control valve actuator evidence is accepted |
| Match Stroke and End Positions | The actuator must achieve full required travel without driving the valve into mechanical stops | Release “Match Stroke and End Positions” only after its electric control valve actuator evidence is accepted |
| Choose Modulating or On-Off Duty | Control valves need suitable positioning resolution, feedback and duty cycle | Release “Choose Modulating or On-Off Duty” only after its electric control valve actuator evidence is accepted |
| Select Control Signal and Feedback | Define floating, voltage or current command, plus position feedback and fault contacts | Release “Select Control Signal and Feedback” only after its electric control valve actuator evidence is accepted |
Five Questions About “Verify Environmental and Manual Operation”
Which “Identify Rotary or Linear Motion” check comes first for electric control valve actuator?
Confirm valve travel, angle, stem interface and direction. Mechanical adapters must transmit motion without lost travel or side loading.
Why does calculate required torque or thrust affect electric control valve actuator?
Use valve data at maximum differential pressure, seal friction and shutoff condition. Apply a documented margin rather than an arbitrary oversized motor.
How should define fail position and power strategy be verified?
Decide what the valve must do on power or signal loss. Spring return, capacitor return or stay-put behavior have different sizing implications.
When must the electric control valve actuator basis be reviewed?
Review electric control valve actuator when inputs to “Identify Rotary or Linear Motion,” “Choose Modulating or On-Off Duty” or “Define Fail Position and Power Strategy” change.
Which details support “Calculate Required Torque or Thrust” in electric control valve actuator?
For electric control valve actuator, provide the inputs for “Identify Rotary or Linear Motion,” the constraints from “Calculate Required Torque or Thrust” and the evidence expected under “Define Fail Position and Power Strategy.”
Before approving “Identify Rotary or Linear Motion,” revisit its project assumptions. Confirm valve travel, angle, stem interface and direction. Mechanical adapters must transmit motion without lost travel or side loading. Record the resulting “Identify Rotary or Linear Motion” decision and any site-specific “Identify Rotary or Linear Motion” exception.
Before approving “Calculate Required Torque or Thrust,” revisit its project assumptions. Use valve data at maximum differential pressure, seal friction and shutoff condition. Apply a documented margin rather than an arbitrary oversized motor. Record the resulting “Calculate Required Torque or Thrust” decision and any site-specific “Calculate Required Torque or Thrust” exception.
Technical references for “Identify Rotary or Linear Motion” include ISA Standards for “Identify Rotary or Linear Motion”, IEC Standards for “Calculate Required Torque or Thrust”, US DOE Pumping Systems for “Match Stroke and End Positions”, CIBSE Knowledge Portal for “Choose Modulating or On-Off Duty”. The project specification should name the applicable edition and local rules.
Dingjia options supporting “Calculate Required Torque or Thrust” include the electric control valve for “Identify Rotary or Linear Motion”, intelligent control valve for “Calculate Required Torque or Thrust”, on/off controller for “Match Stroke and End Positions”, flanged regulating valve for “Choose Modulating or On-Off Duty”. For “Calculate Required Torque or Thrust,” send operating conditions and interface requirements to the engineering team before selection. The inquiry should also assign responsibility for “Select Control Signal and Feedback” and “Check Running Time Against the Process.”